Price history
Recorded standalone sale prices and the latest available store price, in USD. Historical dots use the sale start date and its recorded offer price. Prices can change during a sale; this is not a daily price log. Bundle prices and upcoming offers are excluded. History covers up to the 100 most recent recorded offers.
Lowest recorded standalone price in this history: $29.99. The latest store price is $29.99, matching the lowest recorded price shown here.
View 2 recorded prices
| Sale start / price check | Price | Observation |
|---|---|---|
| $29.99 | Latest store price | |
| $29.99 | Unity First Price 2026-06-25 2026-07-02 |
Sale and bundle history
The 1 most recent recorded offers including this asset. Past offers may no longer be available. Bundle prices cover a package, not this asset alone.
About Swarm AI Toolkit - Avoidance & Steering
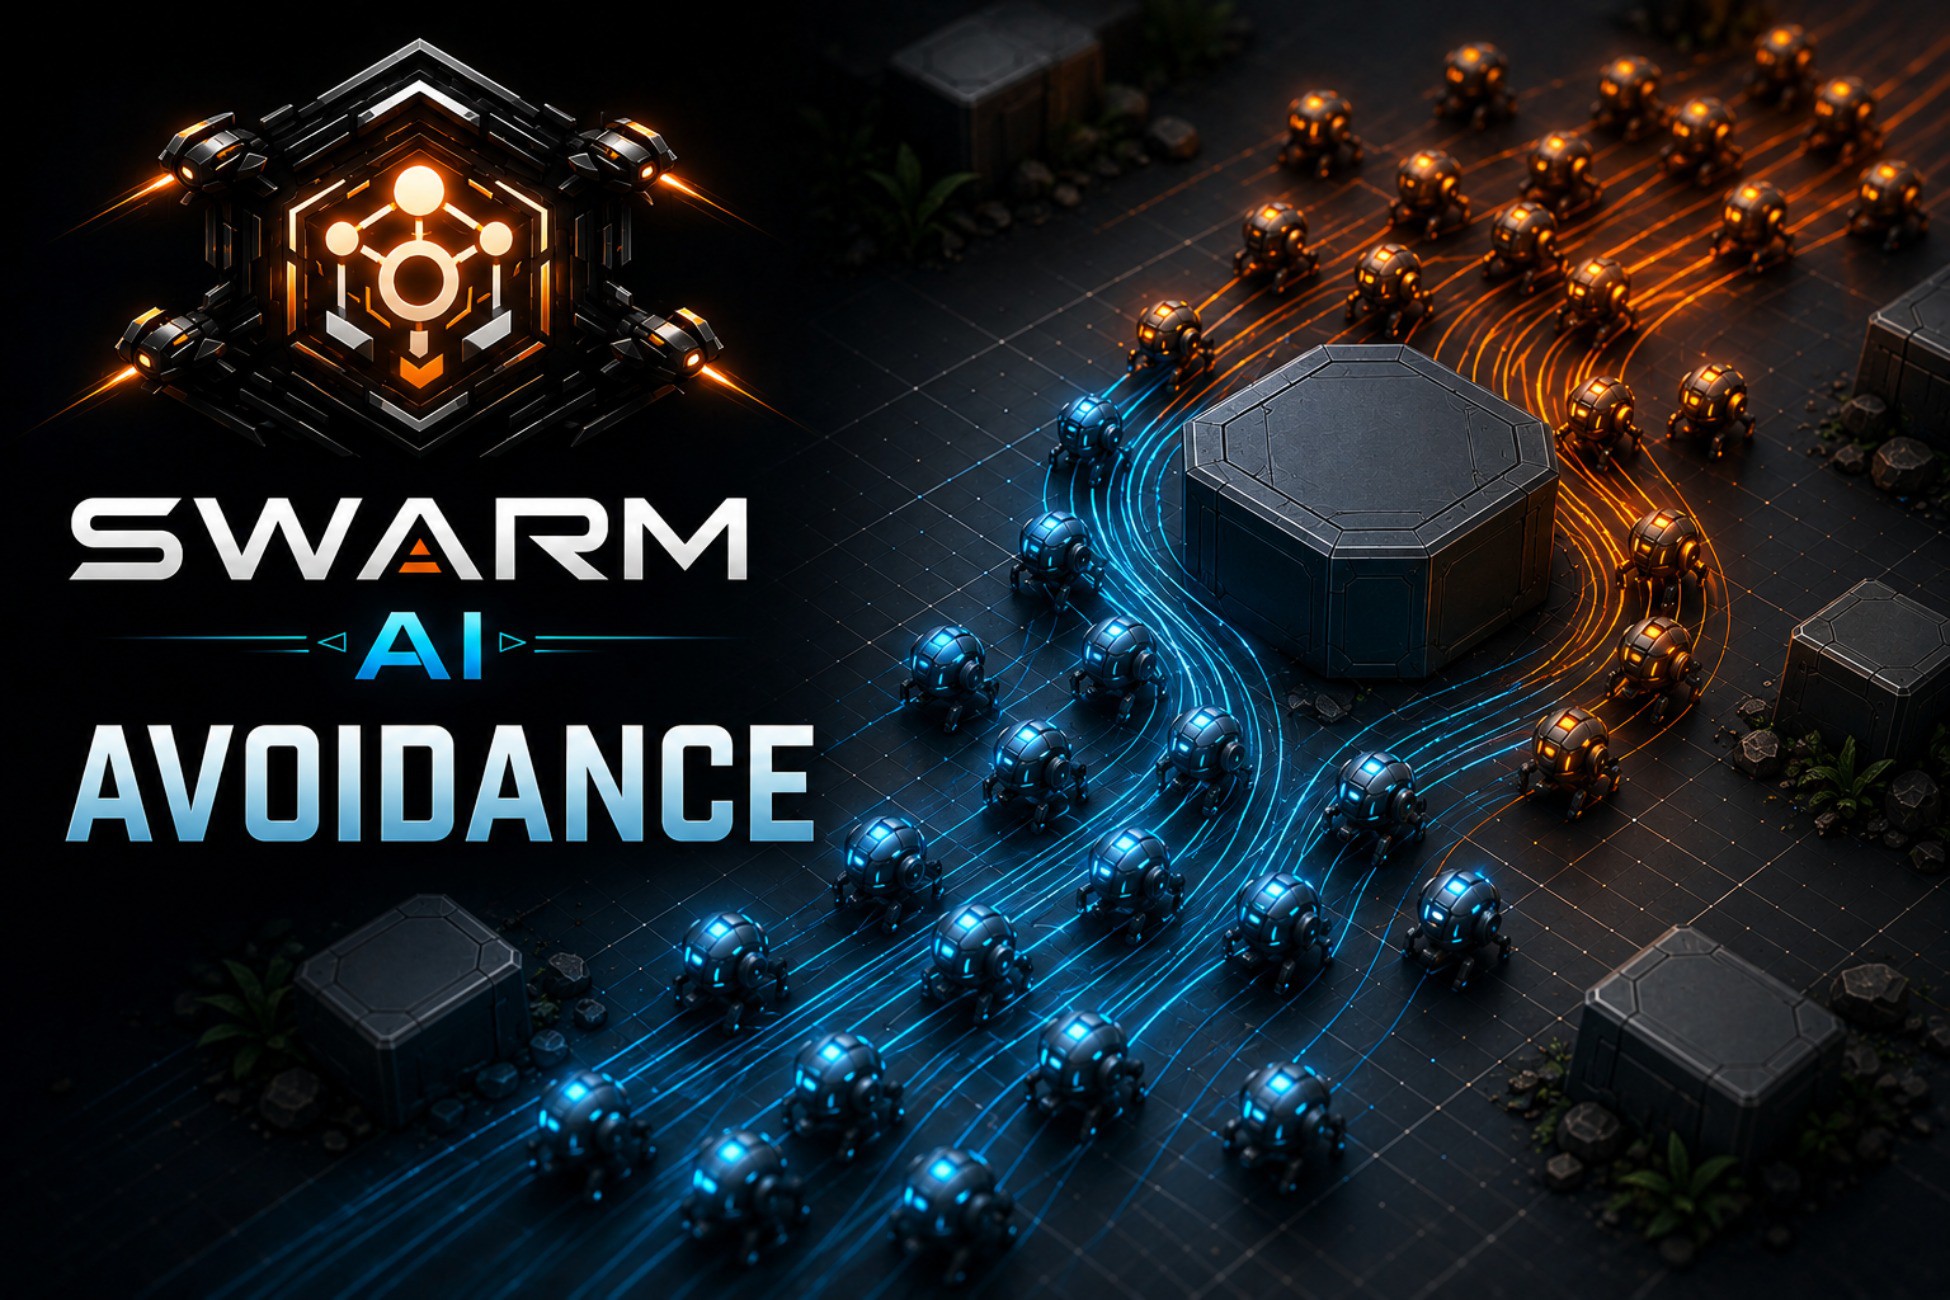
Swarm AI - Avoidance & Steering is a performance-focused local movement layer for crowd, swarm, and formation simulations in Unity. It handles the local side of mass movement: keeping agents responsive, avoiding collisions, reacting to density, and producing motion that feels organic instead of robotic.
This module can be used standalone, or combined with Swarm Core and Flow Fields to build a complete movement stack: global direction, local collision resolution, terrain-aware movement, and natural steering.
What It’s For
- City crowds, top-down games, RTS units, simulations, factories, and creature swarms
- Dense agent scenes where per-agent pathfinding becomes too heavy
- Ground, terrain-following, and flying agents
- Movement systems that need smooth local decisions under load
Key Features
Collision Avoidance
- Predictive local collision avoidance for agent-agent interactions
- ORCA 2D for reciprocal planar avoidance
- ORCA 3D-style avoidance for flying agents
- Continuum crowd avoidance for smooth density-based motion
- Dynamic obstacle avoidance for moving blockers
- Obstacle and cost-field avoidance integrations
Steering Behaviours
- Seek, flee, arrive, follow, pursue, wander, orbit, density, formation, boids, separation, cohesion, and alignment behaviours
- Tunable weights and priorities
- Agent priority support for neighbor interactions
- Avoidance urgency reporting so steering can yield under collision pressure
- Vertical movement preservation for flying agents
Designed To Integrate
- Works standalone as a local steering and avoidance layer
- Integrates with Swarm Core agents through adapters
- Integrates with Flow Fields for global-plus-local navigation
- Supports debug visualization for steering, avoidance, obstacle fields, and cost gradients
- Includes Burst/job-compatible ORCA solver groundwork for optimized workflows
If you want mass movement that looks good, scales well, and avoids heavy per-agent pathfinding, this module is built for that.
This module can be used standalone, or combined with Swarm Core and Flow Fields to build a complete movement stack: global direction, local collision resolution, terrain-aware movement, and natural steering.
What It’s For
- City crowds, top-down games, RTS units, simulations, factories, and creature swarms
- Dense agent scenes where per-agent pathfinding becomes too heavy
- Ground, terrain-following, and flying agents
- Movement systems that need smooth local decisions under load
Key Features
Collision Avoidance
- Predictive local collision avoidance for agent-agent interactions
- ORCA 2D for reciprocal planar avoidance
- ORCA 3D-style avoidance for flying agents
- Continuum crowd avoidance for smooth density-based motion
- Dynamic obstacle avoidance for moving blockers
- Obstacle and cost-field avoidance integrations
Steering Behaviours
- Seek, flee, arrive, follow, pursue, wander, orbit, density, formation, boids, separation, cohesion, and alignment behaviours
- Tunable weights and priorities
- Agent priority support for neighbor interactions
- Avoidance urgency reporting so steering can yield under collision pressure
- Vertical movement preservation for flying agents
Designed To Integrate
- Works standalone as a local steering and avoidance layer
- Integrates with Swarm Core agents through adapters
- Integrates with Flow Fields for global-plus-local navigation
- Supports debug visualization for steering, avoidance, obstacle fields, and cost gradients
- Includes Burst/job-compatible ORCA solver groundwork for optimized workflows
If you want mass movement that looks good, scales well, and avoids heavy per-agent pathfinding, this module is built for that.